Guide
Human-in-the-loop fallback for humanoid and home robots
Shipping a robot before it can do everything alone is a design choice, not a failure. The fallback is what makes it safe and useful from day one.
Updated
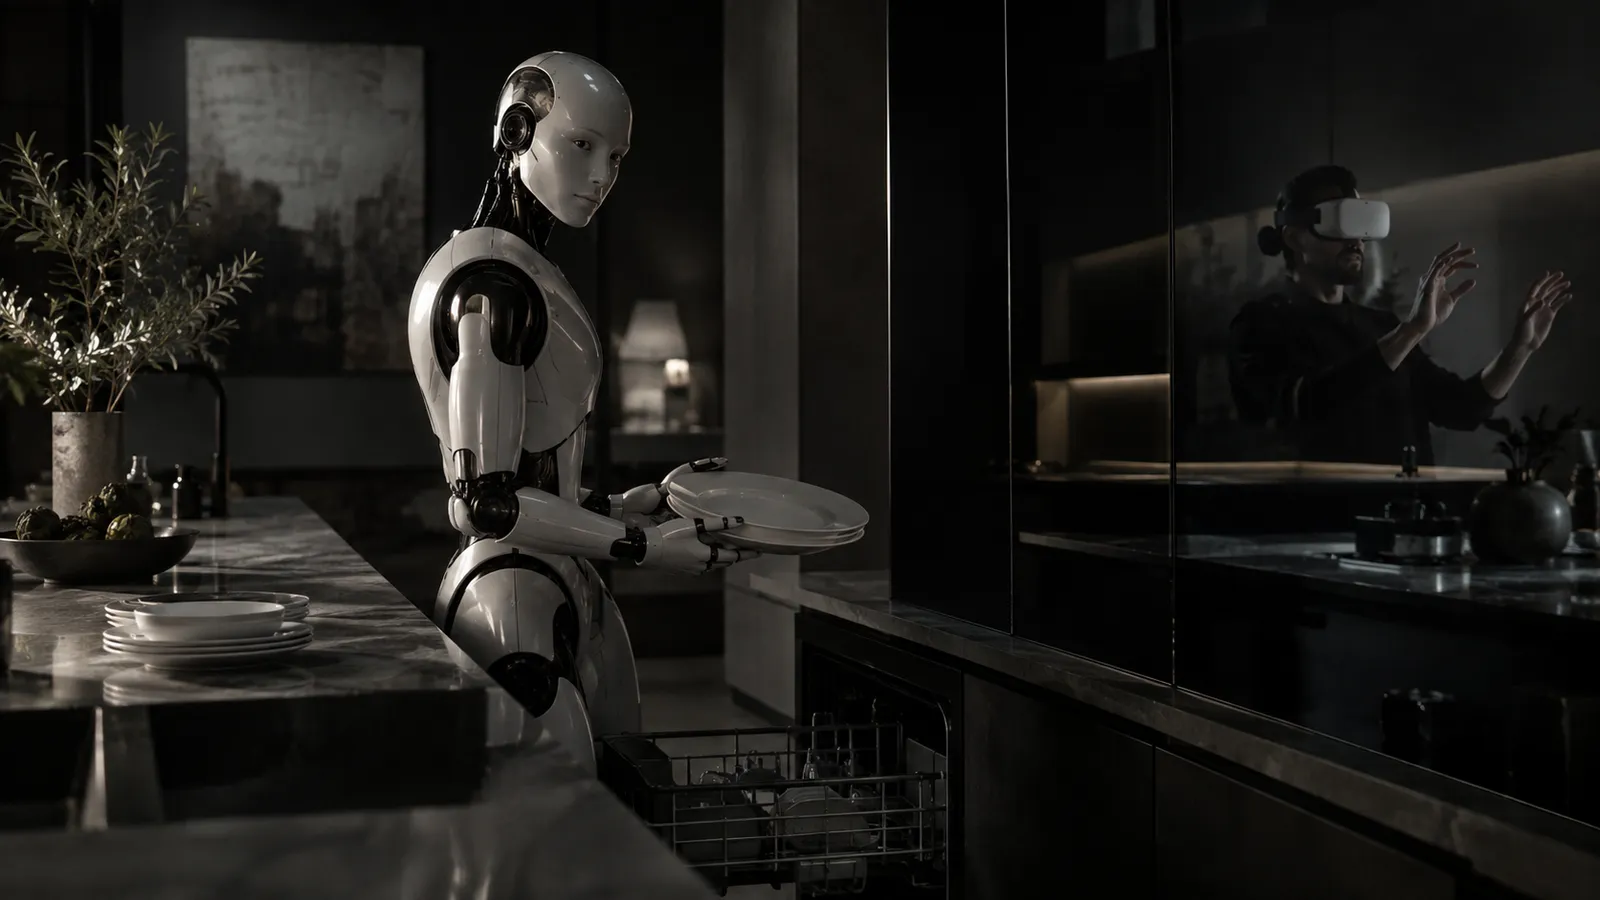
A home or service robot meets situations nobody staged in the lab: an unfamiliar object, a cluttered counter, a door that sticks. A human-in-the-loop fallback lets a trained remote operator take over when the robot is stuck, finish the task, and hand control back. Each of those interventions is also a demonstration of exactly what the policy could not do yet.
Why autonomy needs a fallback
The long tail
Customer trust
Better training data
This pattern is public. 1X has described an Expert Mode for its NEO home humanoid, in which a remote operator takes over tasks the robot cannot complete, with the customer's consent.
Design the escalation
Robot-initiated help requests
Thresholds you can tune
A clean handoff
A local safety layer
Privacy and consent in homes
A remote person seeing inside someone's home is the most sensitive part of this design. Treat it that way from the start.
Staffing the fallback
Coverage has to match when customers use the robots, which for homes means evenings and weekends. The pilot-to-robot ratio depends on how often robots ask for help and how long each intervention lasts. Early fleets often need close to one-to-one attention; as intervention rates fall, one pilot can watch over several robots. Keep the same pilots on your robot so they learn its habits.
Roll it out in stages
Shadow mode
Assisted launch
Steady state
Close the loop with engineering. Every intervention should arrive as a labeled episode with the reason it was needed, so the next training run targets exactly the cases the robot just failed. Teams that skip this step end up paying for the same interventions month after month.
Metrics that show autonomy is improving
Intervention rate
Time to takeover
Task success with and without help
Intervention reasons
RoboPilots pilots are trained on your robot, take over whenever it asks for help, and every intervention comes back as a labeled episode your policy can learn from.
Frequently asked questions
- What is a human-in-the-loop fallback for robots?
- A setup where a trained remote operator takes control when the robot cannot finish a task on its own, completes it, and hands control back.
- Do remote operators see inside customers’ homes?
- Only with consent and only what the task requires. Good designs show when someone is connected, mask what is not needed and log every session.
- How many robots can one remote operator cover?
- It depends on how often robots ask for help. Early fleets may need close to one pilot per robot; as intervention rates fall, one pilot can cover several.
- Does the fallback help the robot learn?
- Yes. Each intervention is a demonstration on a real failure case, which is valuable training data when it is recorded and labeled.
- What happens if the network drops during a takeover?
- The robot’s local safety layer takes over: it stops or holds position within its collision and force limits until the link returns. Remote control should never be the only safety mechanism.
- Which tasks are best suited to remote takeover?
- Tasks where a person can judge quickly from the robot’s cameras, such as identifying an unfamiliar object, choosing a grasp or clearing a cluttered surface. Tasks that need fast reflexes at long distance are better handled by on-robot autonomy.